Object detection with Faster R-CNN
An object detector using region proposals and a pretrained VGG16 backbone.
Detector architecture
I implemented the region proposal network, RoI pooling, classification head, box regression, and the end-to-end loss around the course-provided pretrained VGG16 backbone. Each feature-map location uses nine anchors across three scales and three aspect ratios. At test time, non-maximum suppression filters duplicate boxes.
Training and evaluation
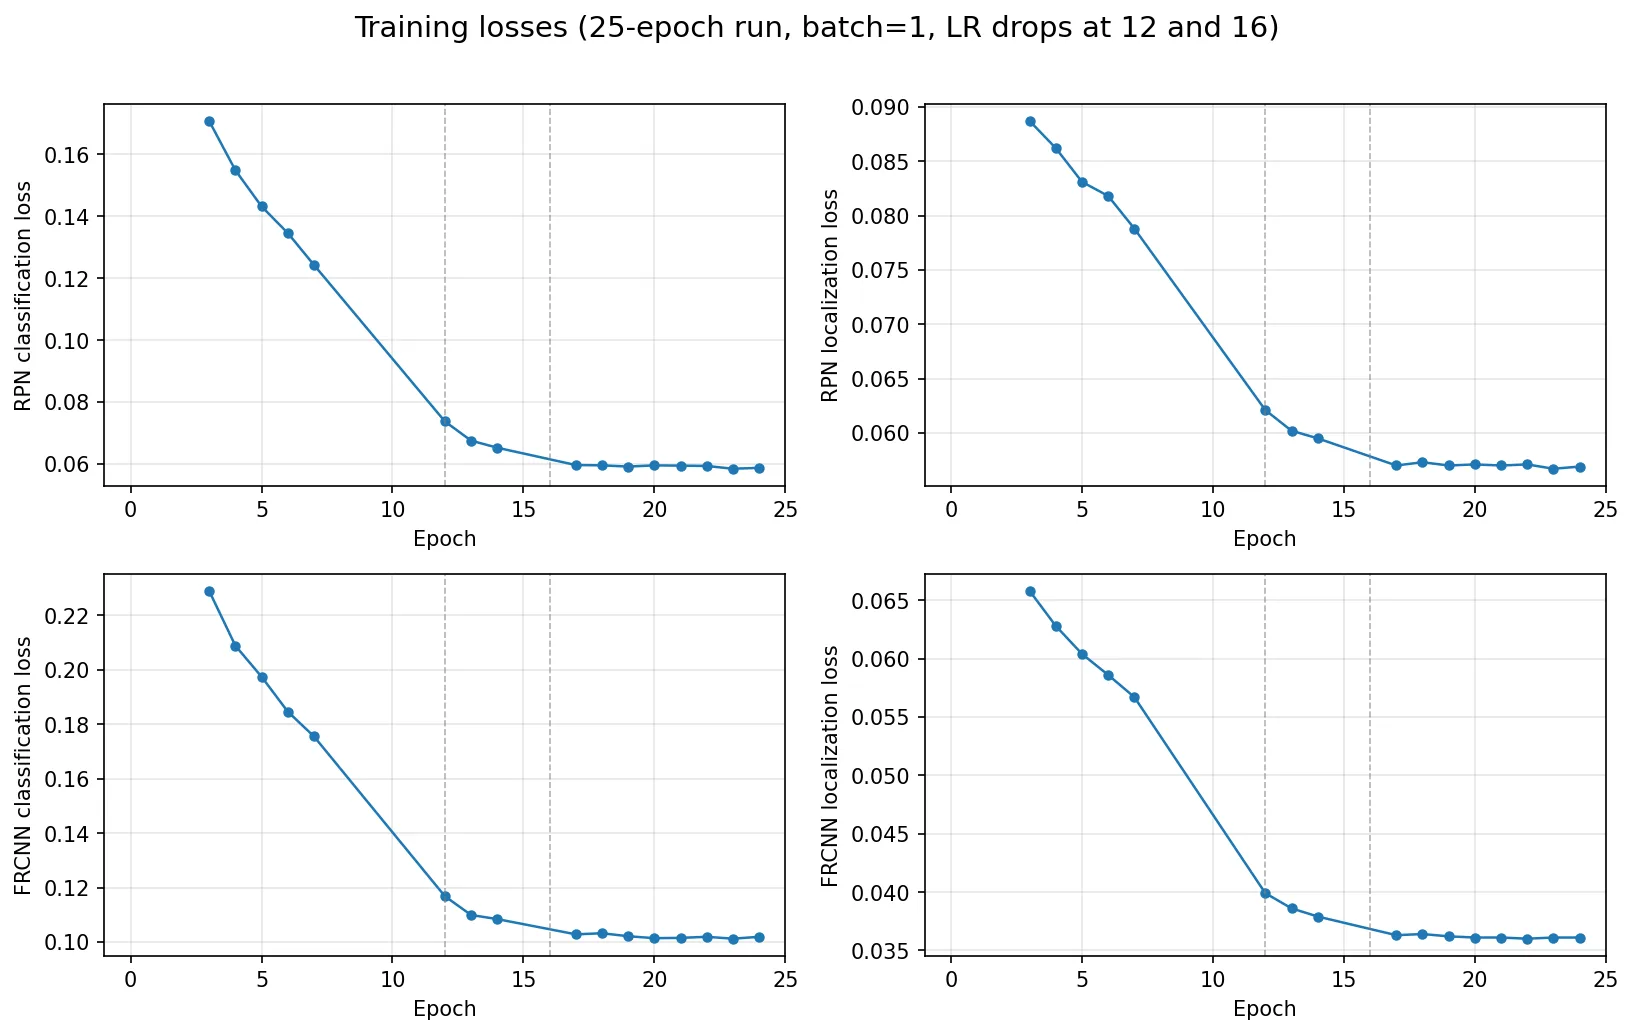
The detector trained on VOC2007 trainval, with 5,011 images, and was evaluated on the 4,952-image test split at IoU 0.5. After 25 epochs, it reached 0.6086 mean average precision across the 20 VOC classes. The curves show the four loss terms settling after the scheduled learning-rate reductions.
Detection examples
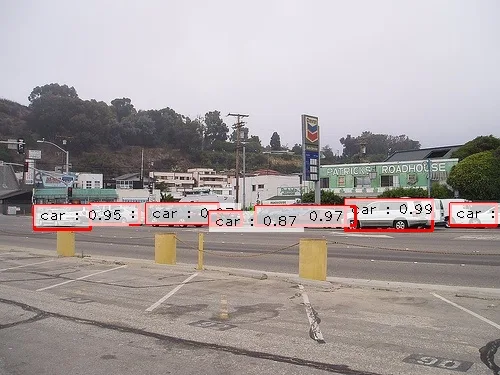
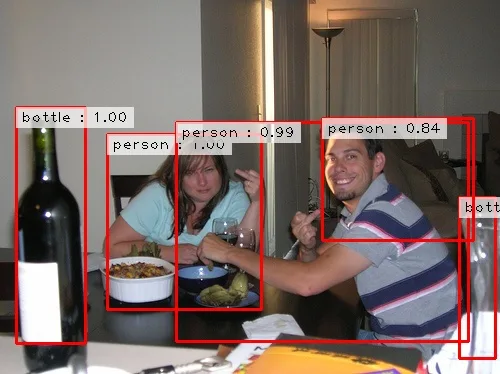
The retained checkpoint finds multiple instances in crowded test images, including five parked cars and a dining-table scene with bottles and people. These are raw assignment outputs after per-class non-maximum suppression.
Why I kept the shorter run
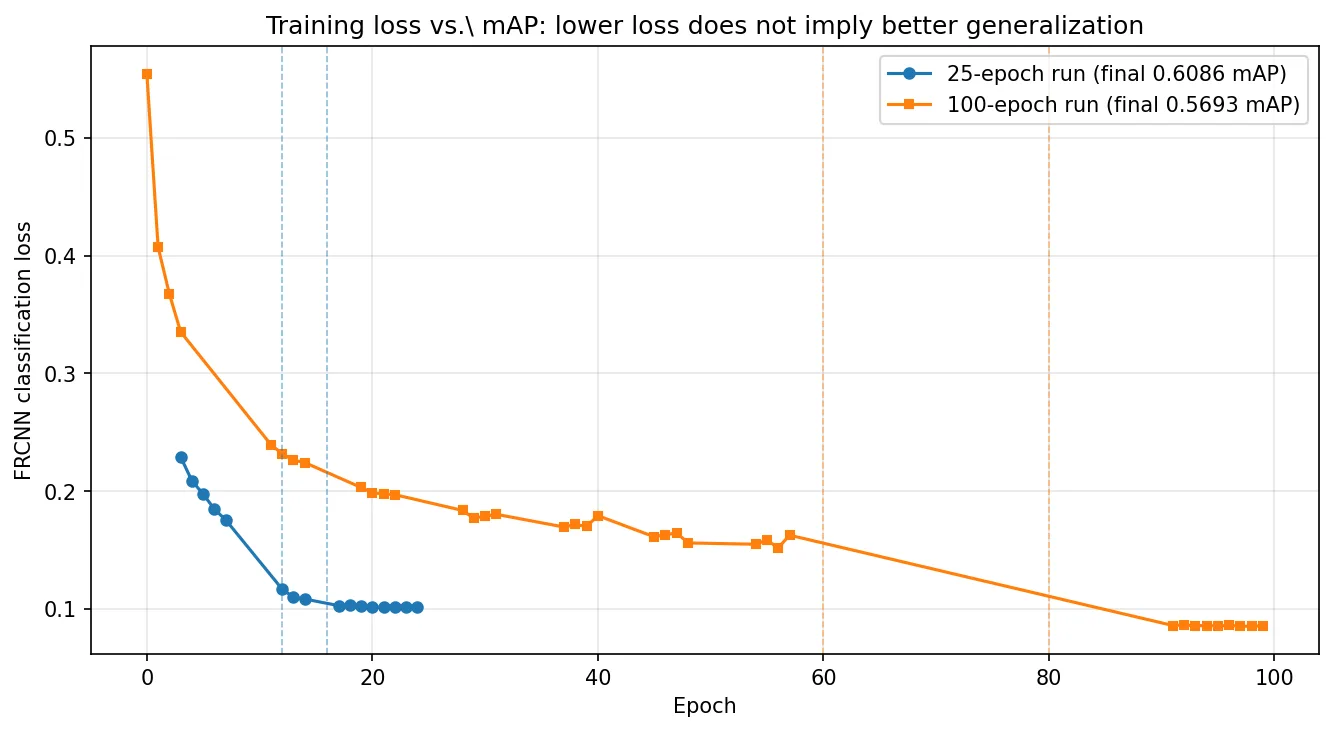
A 100-epoch follow-up lowered the training classification loss but reduced test mAP from 0.6086 to 0.5693. I kept the 25-epoch checkpoint because the longer run generalized worse on the held-out test set.